Runway Introduces Praxis-1 World Action Model for Robotics
Runway AI Inc. has introduced Praxis-1, an open-weight world action model designed to translate large-scale video pretraining into direct robotic control.
 Radwan AbdulhadiEditor and technology writer
Introduction to Praxis-1
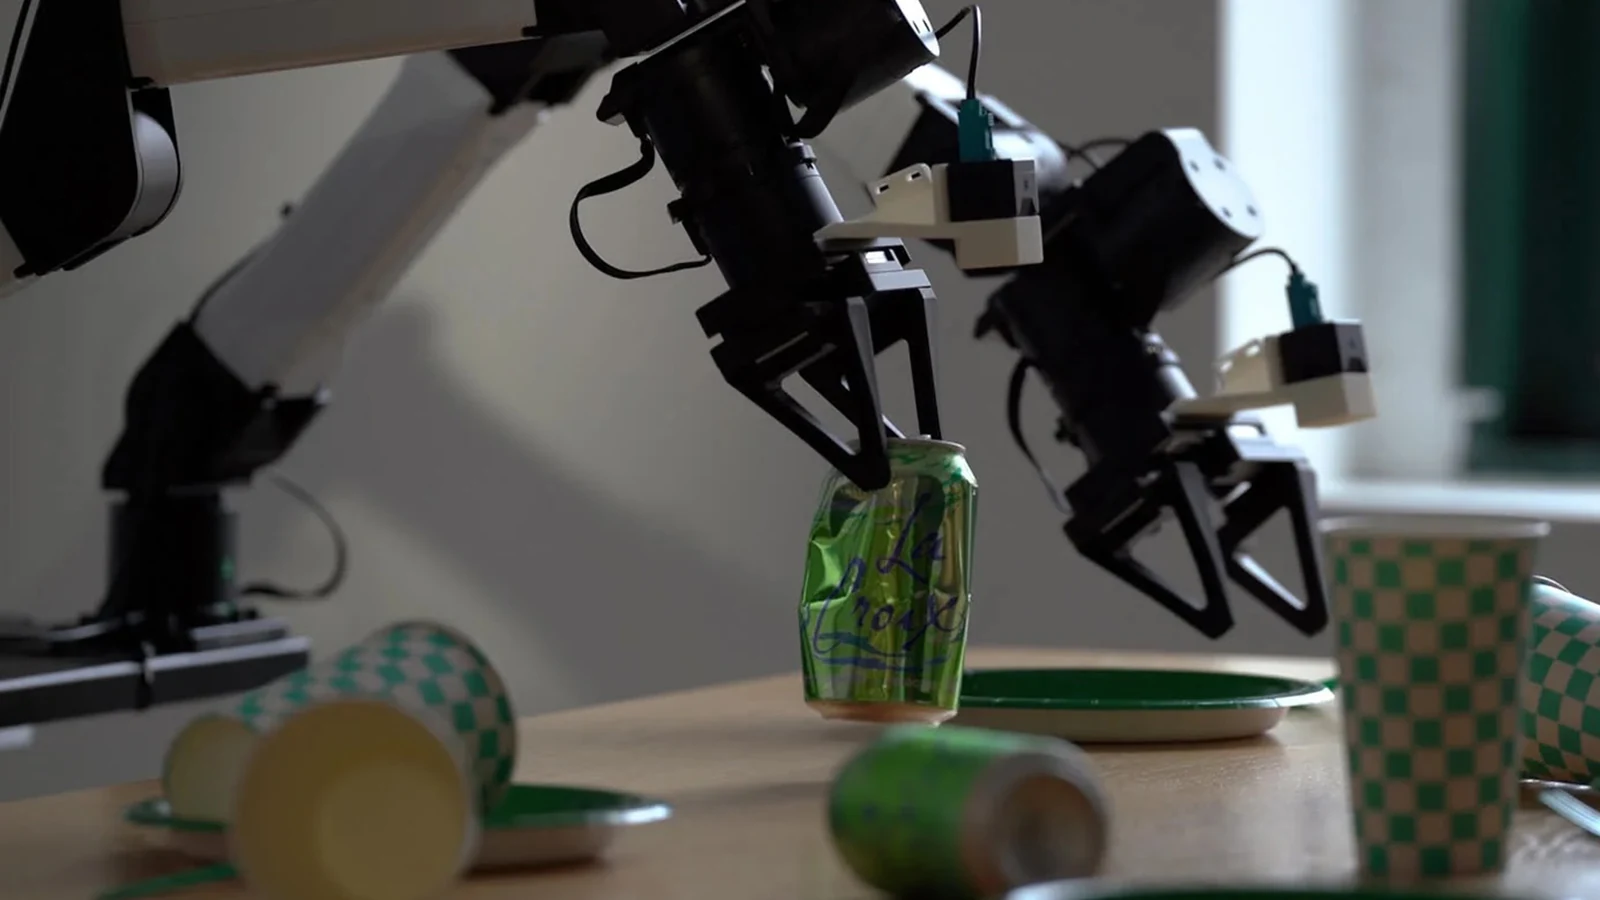
Runway AI Inc. introduced Praxis-1, an open-weight world action model that converts Runway's video pretraining into control for robots. Founded in 2018, the company specializes in generative artificial intelligence research and technologies, offering a range of models such as Aleph 2.0 for video editing, Act-Two for motion capture, and Gen-4.5 for text-to-video and image-to-video generation. For the robotics sector, the Brooklyn, New York-based company also offers GWM-1, a general world model.
According to Kamil Sindi, Runway's chief technology officer, most robot policies are bottlenecked by robot data, which is scarce and expensive to collect. Praxis-1 learns primarily from third-person video, drawing on the same large-scale pretraining behind Runway's world models so that it already understands how objects behave and how tasks unfold.
Overcoming Data Scarcity Through Video Pretraining
While there is a shortage of real-world robotics data to train generalist AI models, there is an abundance of video data available. Runway AI noted that everyday people film and upload more footage of daily life each day than any robot lab could capture through teleoperated demonstrations. Because performance improves as video scales, the ceiling for Praxis-1 is determined by how much video it can learn from rather than the number of available robot demonstrations.
Runway has extended its work on pretraining large video models into interactive, real-time video models like Solaris and GWM Worlds 2. By teaching models how to generate accurate physics, how hands move, and what a task looks like partway through, the company has created dynamic environments for agent training in both digital and physical spaces. Runway states that Praxis-1 brings this exact approach to robotics, offering a generalist policy model for developers and researchers that functions across any embodiment or environment.
Early Testing and Partner Deployment
Runway is rolling out Praxis-1 to key partners prior to a general public launch, with intentions to provide access to additional partners ahead of time. Sindi noted that early partners including Noble Machines, Standard Bots, and Ultra are currently running Praxis-1 on their own hardware configurations.
A major takeaway from the initial testing phase has been that a single model can adapt across very different embodiments, ranging from bimanual arms to humanoids, requiring only light fine-tuning. This partner testing is helping Runway identify and close potential gaps prior to achieving general availability across the broader market.
Open-Weight Strategy and Future Plans
When Runway does release Praxis-1 publicly, the company plans to ship it with open weights instead of as a closed model. Sindi emphasized that open weights give hardware developers the flexibility and control they require, aligning with the belief that U.S. leadership in physical AI is essential for regaining a manufacturing lead.
Looking forward, Runway intends to continue testing and evaluating Praxis-1 with partners, bring on additional early-access collaborators, and carefully assess efficacy and safety across diverse embodiments and environments before the full public launch.
Sources
- The Robot ReportRunway introduces Praxis-1 world action model for robotics
Continue chronologically
Related stories
NVIDIA AI Factories Maximize ROI Through Productivity and Durability
NVIDIA details how AI factories maximize return on investment by delivering high throughput, extending hardware useful life, and supporting diverse workloads.
Inside Omron’s Next-Generation LD Mobile Robots
Explore Omron's next-generation LD mobile robots and discover why software, safety, and fleet management are crucial for modern automation.
Cloudflare Launches Traces in Open Beta for End-to-End Request Visibility
Cloudflare has introduced Cloudflare Traces in open beta, extending automated request tracing across security rules, caches, Workers, and origin infrastructure.
The State of Robots and Automation in Modern Manufacturing
Explore the latest advances in manufacturing robotics, covering growth in industrial automation, collaborative robots, and global adoption trends.